More from IFIP International Conference on Entertainment Computing (ICEC)
View all
Whitepaper
Seligman's PERMA Model in Video Games: The Positive Influence of Video Games on Well-Being
IFIP International Conference on Entertainment Computing (ICEC) · 2023
Whitepaper
Augmented Adventures: Using Different Perspectives to Design Novel Tabletop Game Experiences
Springer · 2023
Whitepaper
Through Troubled Waters: A Narrative Game for Anger Regulation
IFIP International Conference on Entertainment Computing (ICEC) · 2022
Whitepaper
Linkages Between Gameplay Preferences and Fondness for Game Music
IFIP International Conference on Entertainment Computing (ICEC) · 2021
Whitepaper
The Gilmorehill Mystery: A Location-based Game for Campus Exploration
University of Glasgow · 2021
Whitepaper
Analysis of the Effect of Number of Players on the Excitement of the Game with Respect to Fairness
IFIP International Conference on Entertainment Computing (ICEC) · 2018
Whitepaper
Naturalized Motion Generator for NPC in 3D Game
IFIP International Conference on Entertainment Computing (ICEC) · 2017
Whitepaper
Design and Evaluation of a Cybersecurity Awareness Training Game
IFIP International Conference on Entertainment Computing (ICEC) · 2017
Whitepaper
A Brief History of Serious Games
IFIP International Conference on Entertainment Computing (ICEC) · 2016
Whitepaper
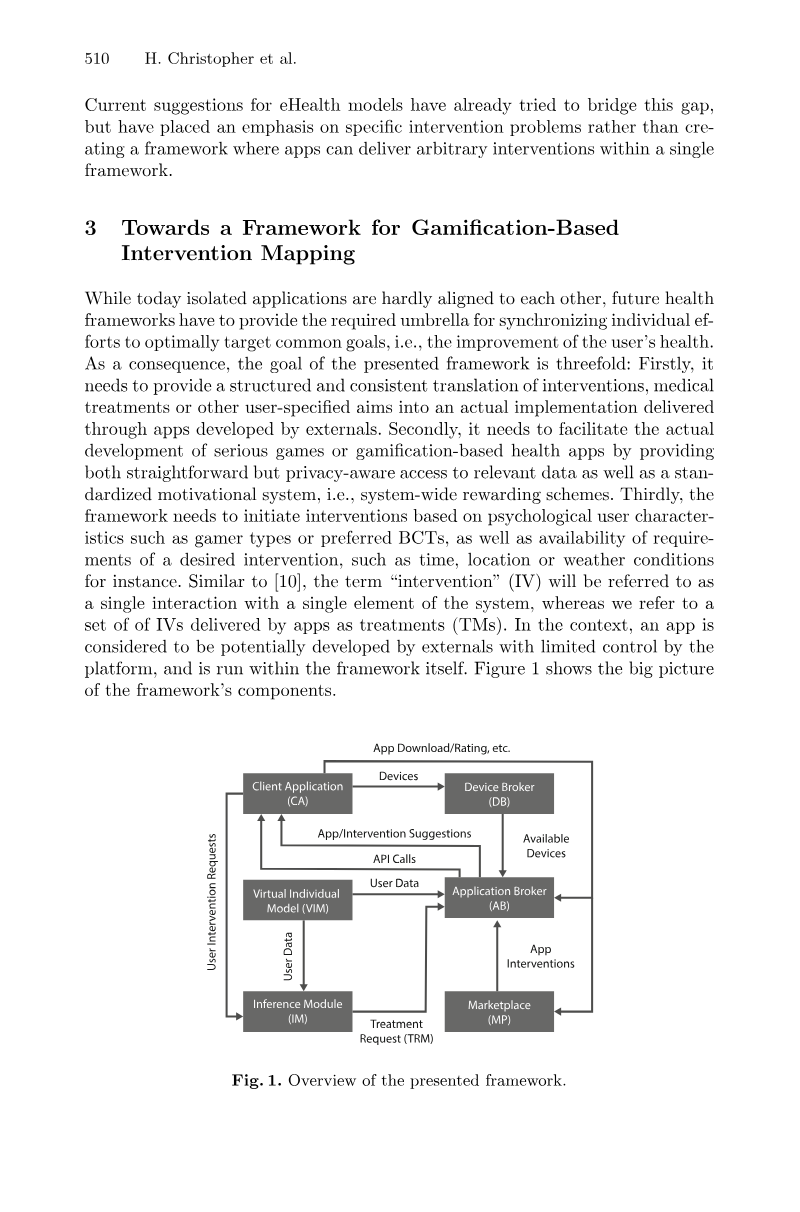
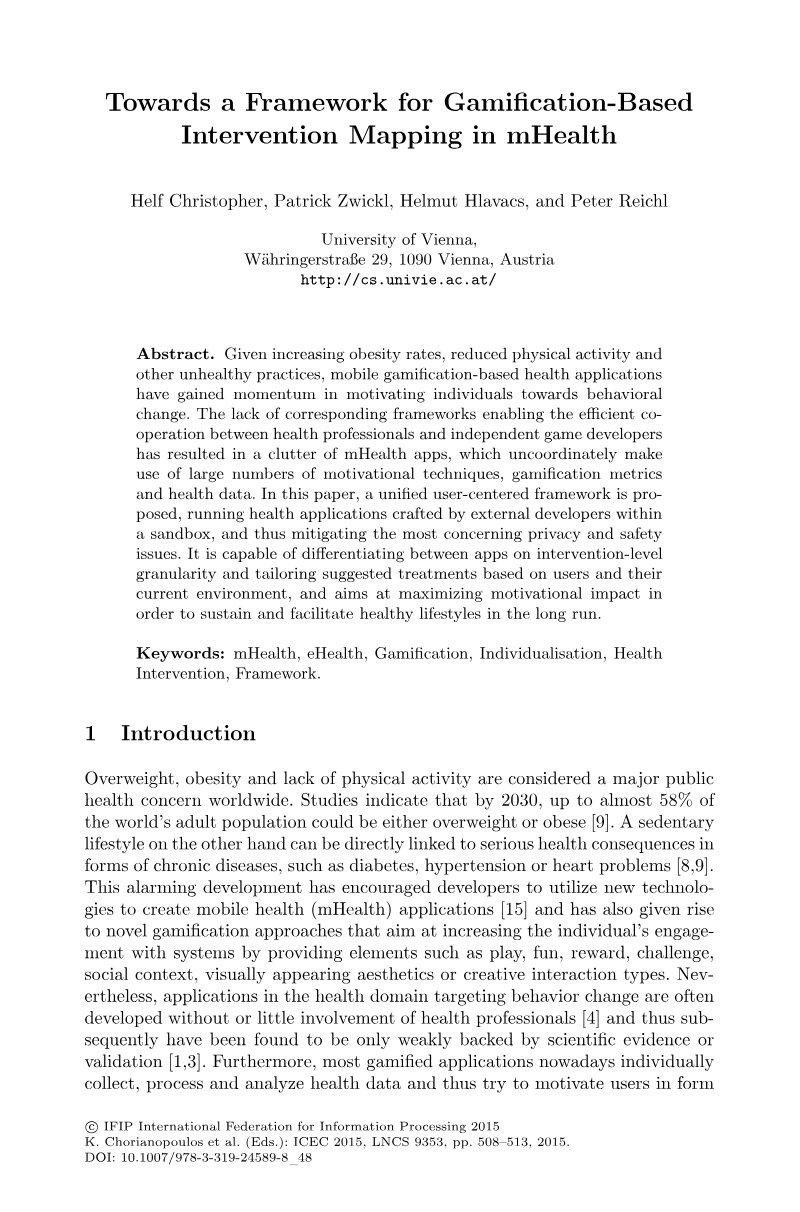
Towards a Framework for Gamification-Based Intervention Mapping in mHealth
University of Vienna · 2015
Whitepaper
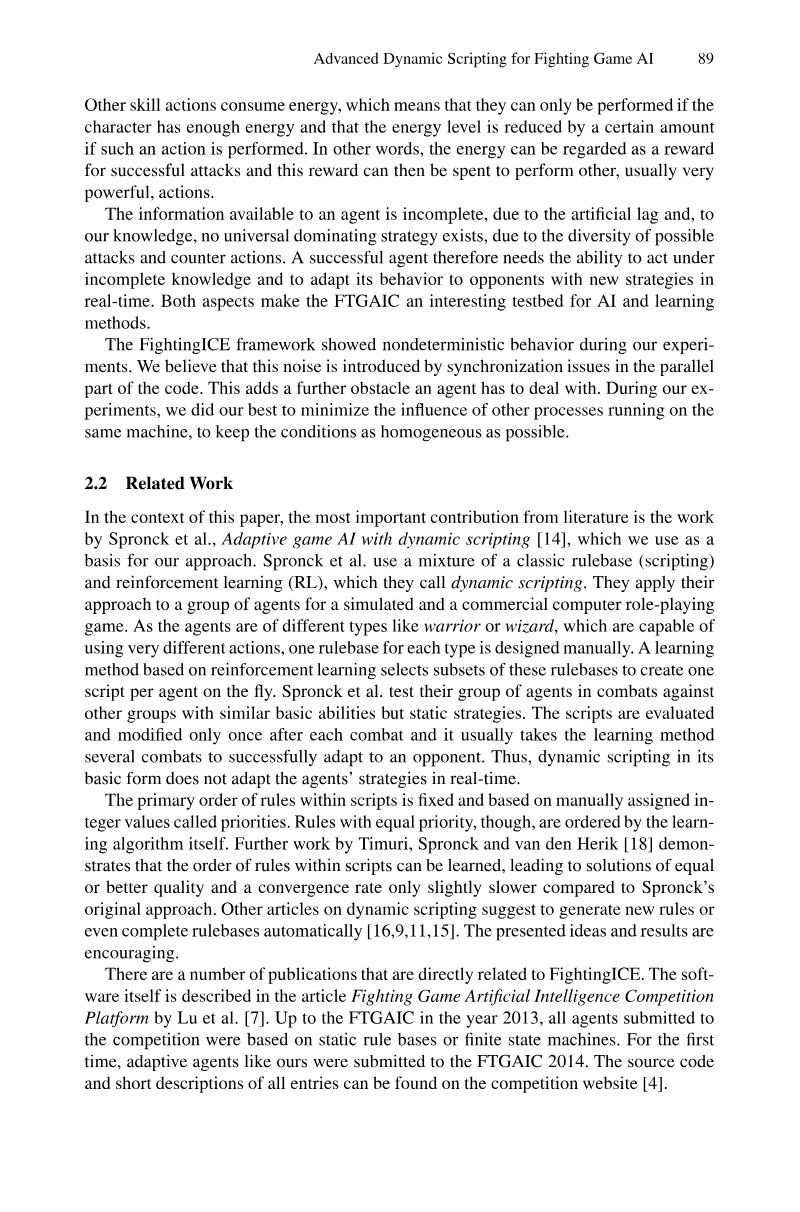
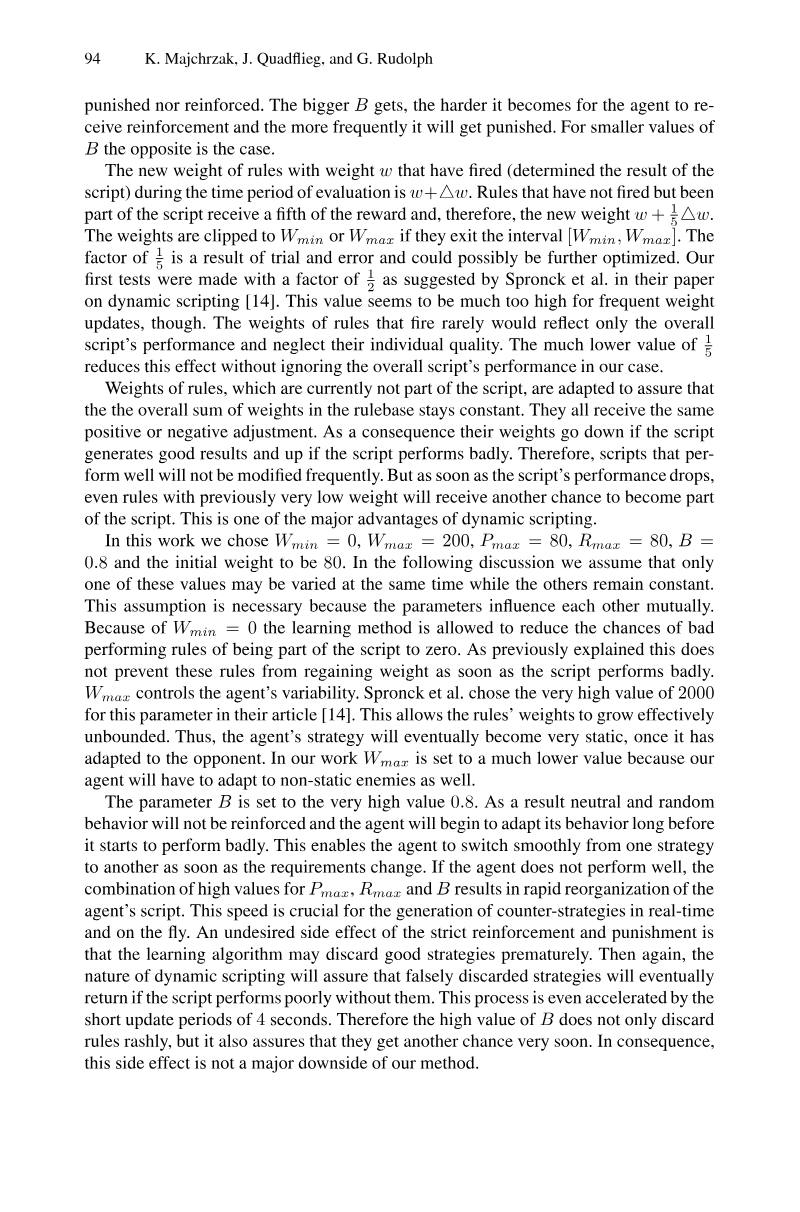
Advanced Dynamic Scripting for Fighting Game AI
IFIP International Conference on Entertainment Computing (ICEC) · 2015
Whitepaper
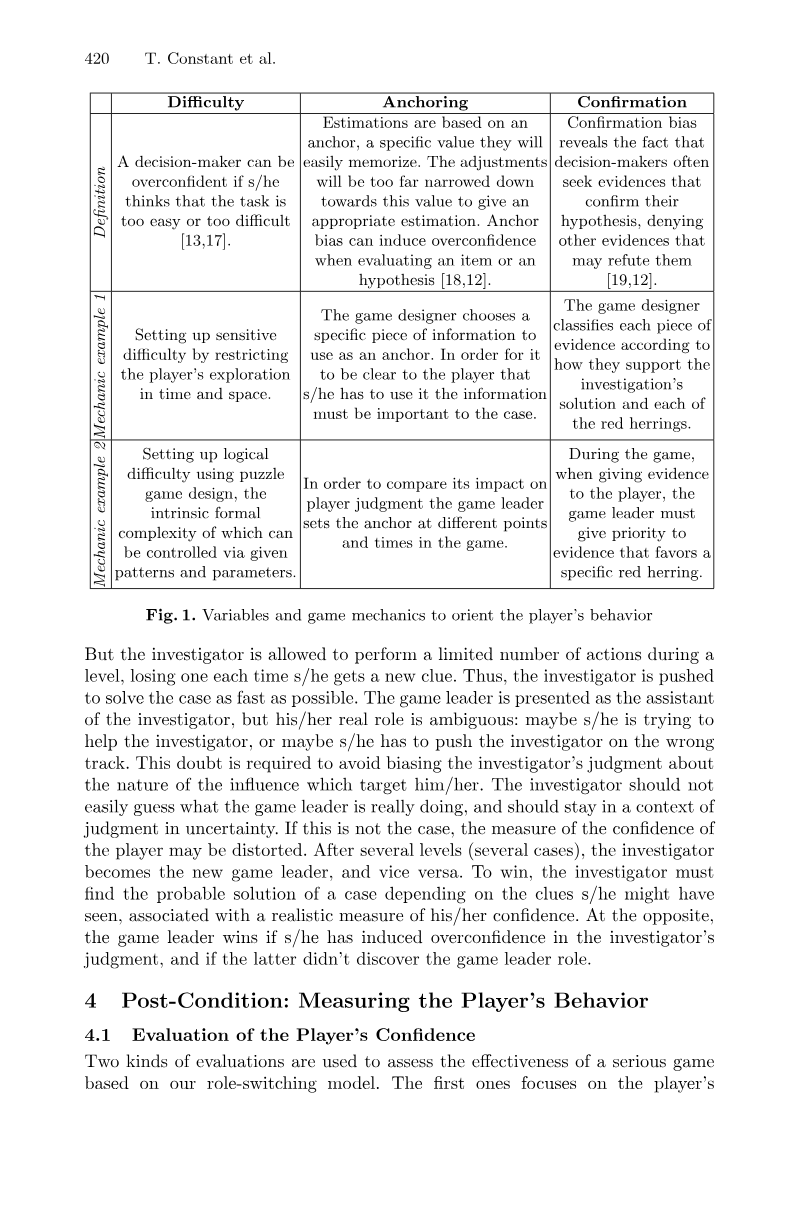
A Role-Switching Mechanic for Reflective Decision-Making Game
IFIP International Conference on Entertainment Computing (ICEC) · 2015
More on VR
View all
Whitepaper
Extending The Project Win Game: Teaching Real Options and Moral AI Project Decision-making
maxmetrics · 2026
Whitepaper
An Early-Stage Feasibility and Usability Pilot for an Immersive Serious Game to Support English Spelling and Semantic Skills
European Conference on Games Based Learning (ECGBL) · 2026